Ontology Parameters:
RX75S Series Parameters and D-H Model Basic Parameters
| Parameter Name | Parameter Value | |
|---|---|---|
| Basic Parameters | Degrees of Freedom | 7 |
| Joint Brake Type | Joints 1~4: Hard Brake Joints 5~7: Soft Brake | |
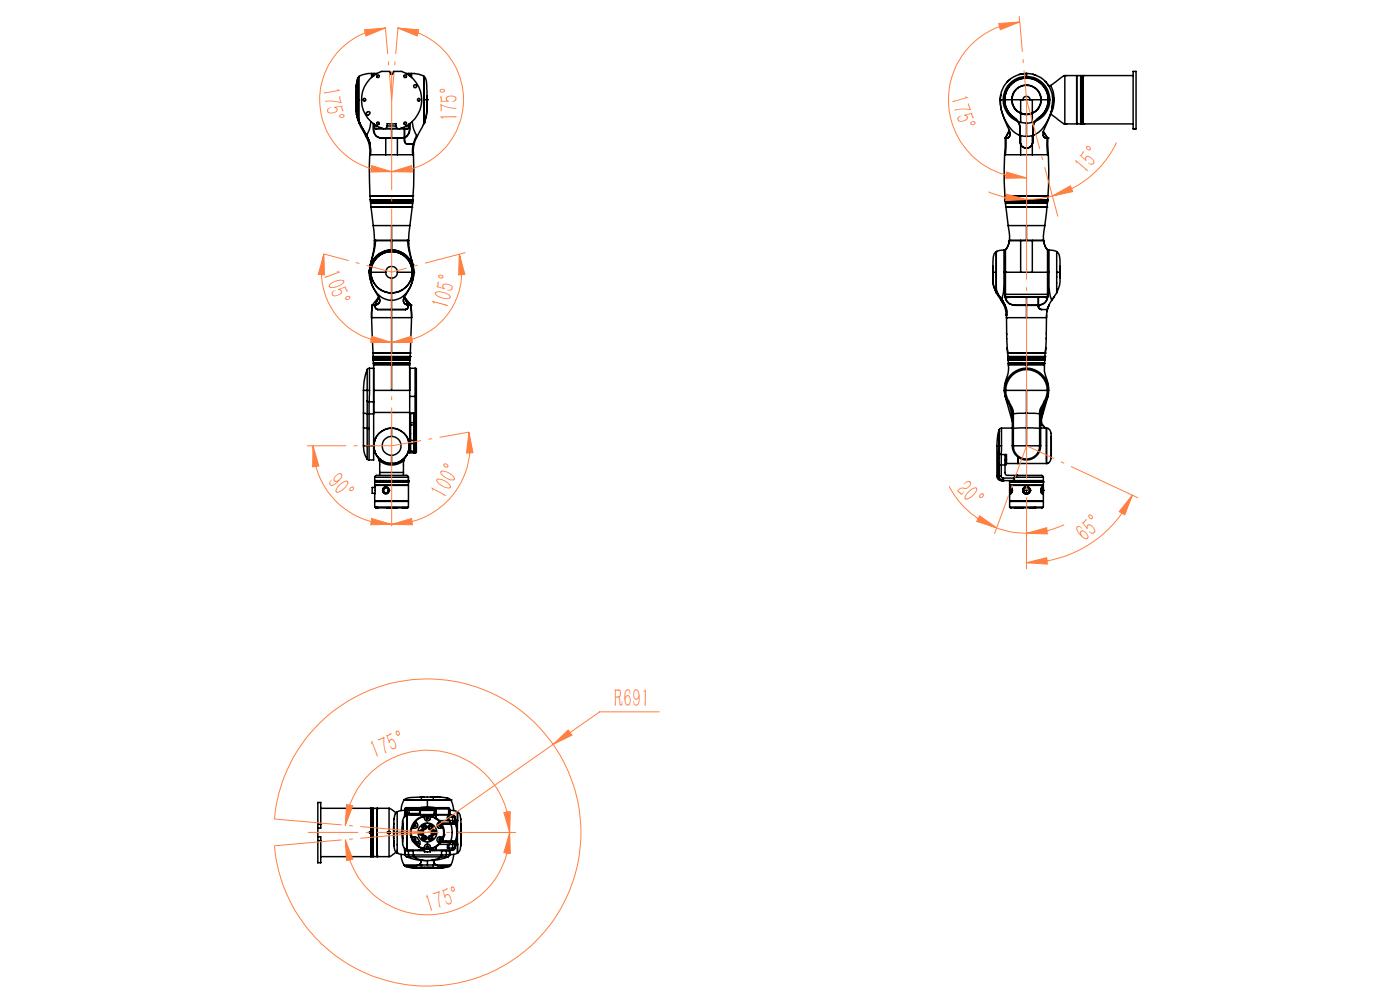
| Working Radius/mm | 691 | |
| Effective Rated Payload/kg | 5 | |
| Self-weight/kg | 8.97 | |
| Repeatability/mm | ±0.1 | |
| TCP Line Speed/m/s | ≤1.8 | |
| Typical Power/W | ≤200 | |
| Instant Peak Power/W | ≤600 | |
| Base Dimensions/mm | φ102 | |
| Material | Aluminum Alloy/ABS | |
| Environmental Adaptability | Working Temperature/℃ | 0~45 |
| Working Humidity | 25~85% No Condensation | |
| Motion Range/° | J1 | -175~+175 |
| J2 | -15~+175 | |
| J3 | -175~+175 | |
| J4 | -105~+105 | |
| J5 | -170~+170 | |
| J6 | Left Arm: -65 ~ 20 Right Arm: -20 ~ 65 | |
| J7 | Left Arm: -100 ~ 90 Right Arm: -90 ~ 100 | |
| Maximum Angular Velocity/ °/s | J1 | 180 |
| J2 | 180 | |
| J3 | 225 | |
| J4 | 225 | |
| J5 | 225 | |
| J6 | 225 | |
| J7 | 225 | |
Ontology Parameters
Left Arm MDH Model Frame:
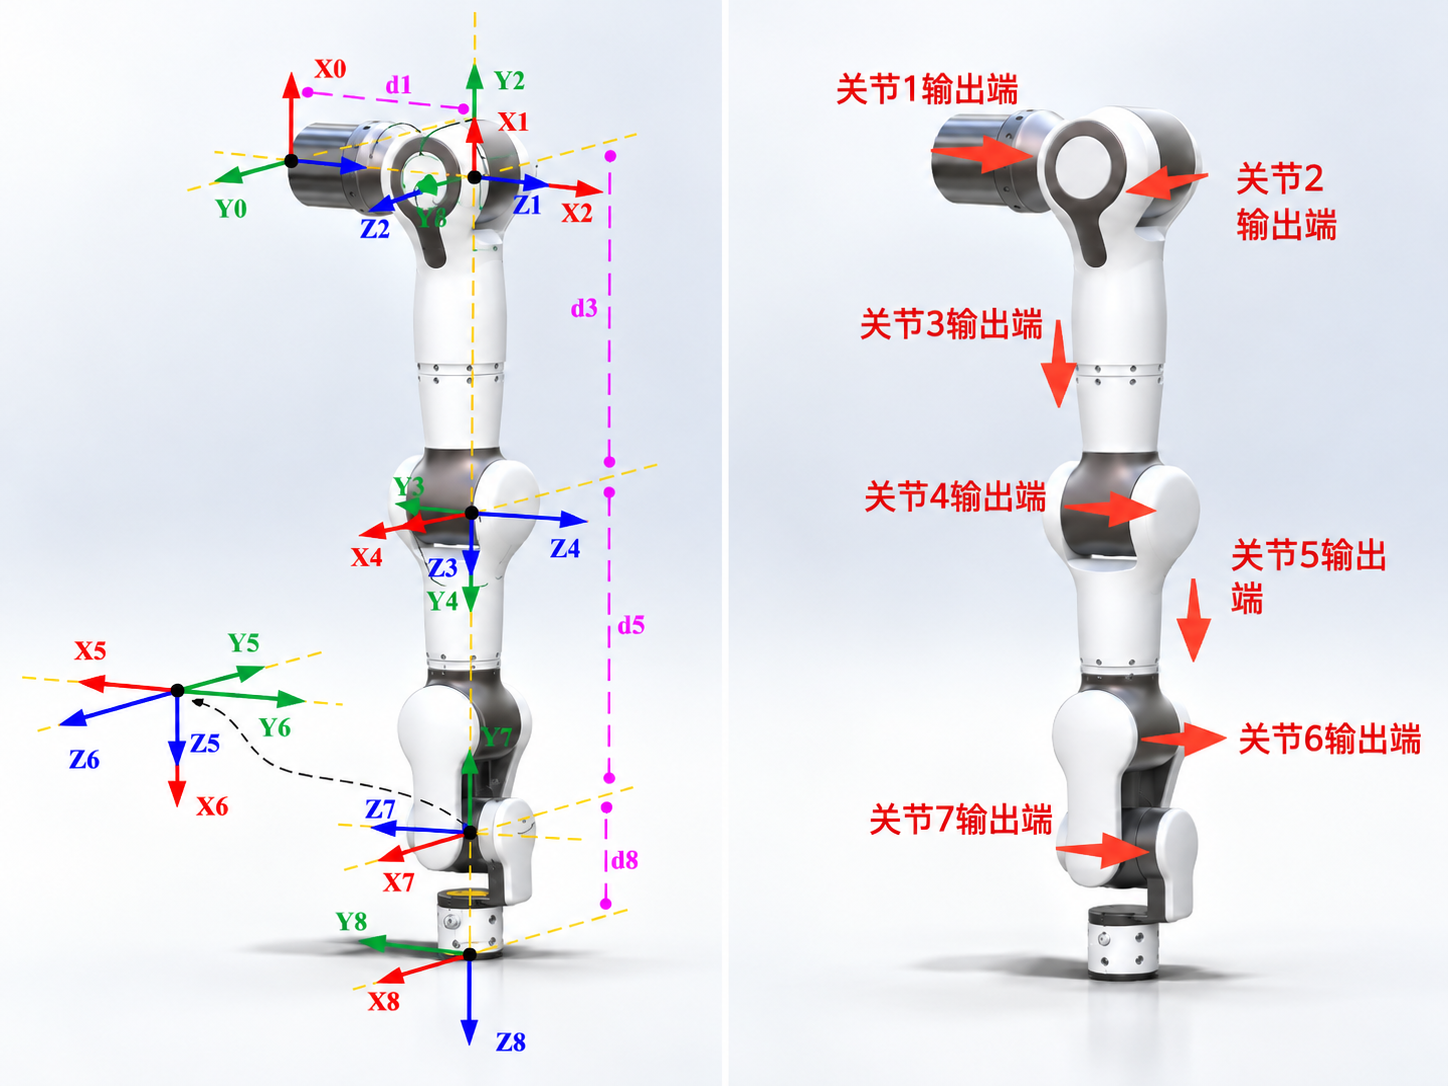
Left Arm RXL75S Series MDH Parameters (Modified D-H Parameters):
Installation information: Ry=-90°
| joint_id(i) | Remarks | ||||
|---|---|---|---|---|---|
| 1 | 0 | 0 | 185.5 | 0 | |
| 2 | 0 | -90 | 0 | -90 | |
| 3 | 0 | 90 | 292 | 90 | |
| 4 | 0 | 90 | 0 | 0 | |
| 5 | 0 | -90 | 294 | 90 | |
| 6 | 0 | 90 | 0 | 90 | |
| 7 | 0 | 90 | 0 | 90 | |
| 8 (Virtual Axis) | 0 | 90 | 105 | 0 | (6F) Integrated 6-DoF Force |
Note: offset is the deviation between the mechanical zero position and the modeling zero position, i.e. model angle = joint angle + offset.
Right Arm MDH Model Frame:
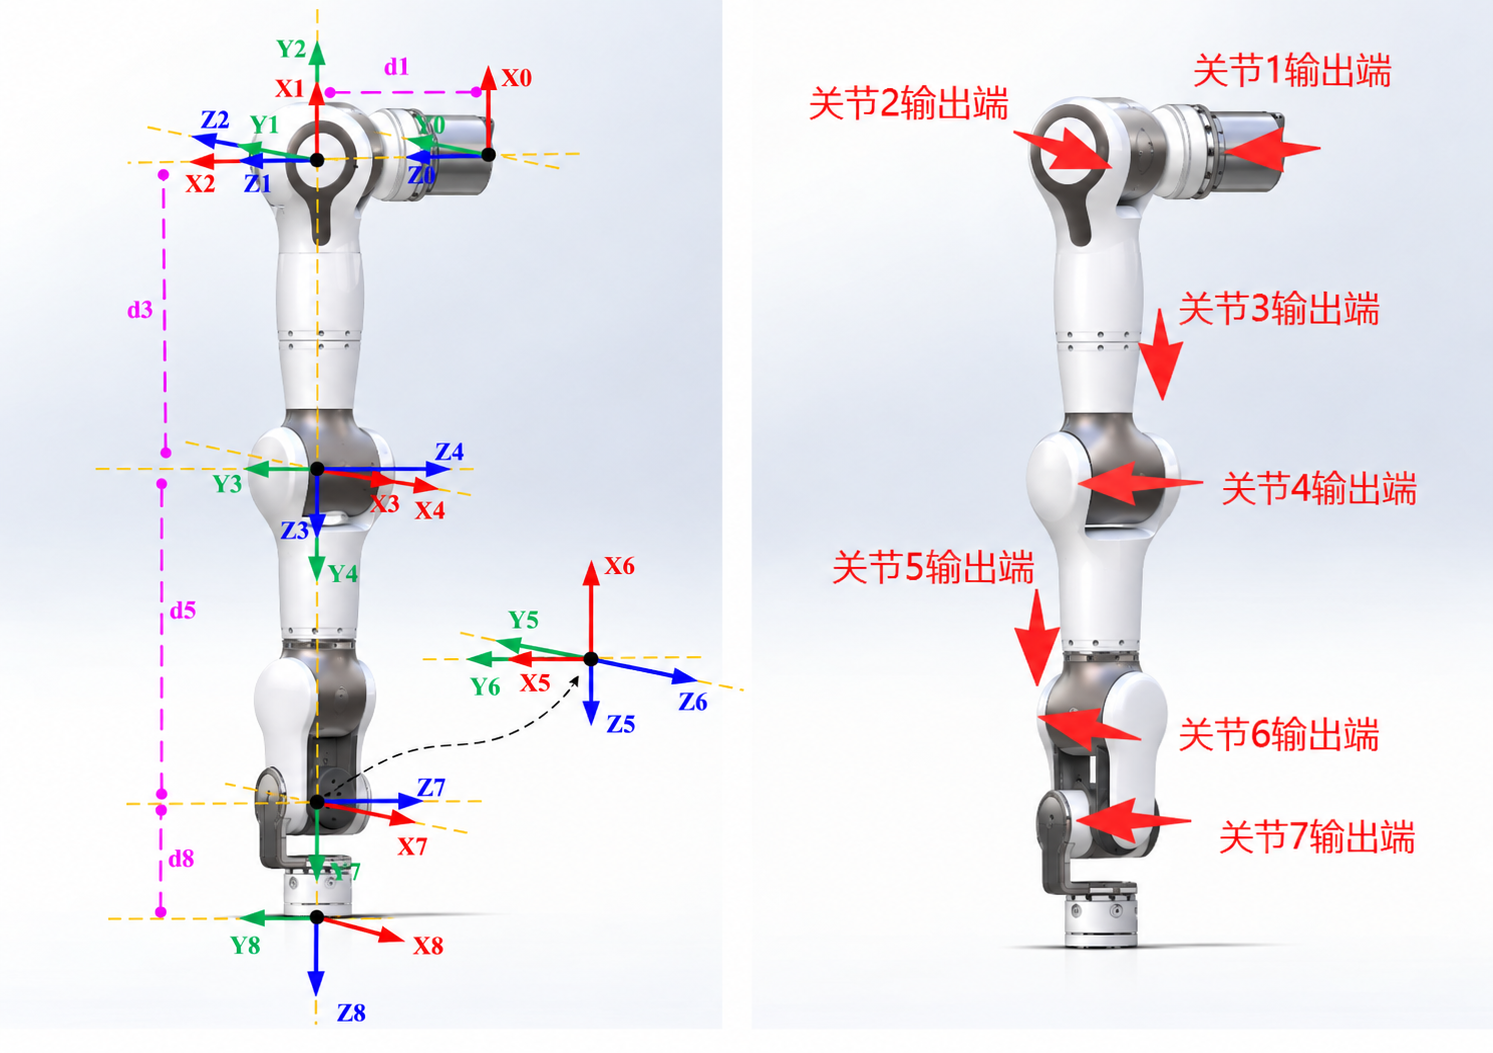
Right Arm RXR75S Series MDH Parameters (Modified D-H Parameters):
Installation information: Ry=-90°
| joint_id(i) | Remarks | ||||
|---|---|---|---|---|---|
| 1 | 0 | 0 | 185.5 | 0 | |
| 2 | 0 | -90 | 0 | -90 | |
| 3 | 0 | 90 | 292 | -90 | |
| 4 | 0 | 90 | 0 | 0 | |
| 5 | 0 | -90 | 294 | 90 | |
| 6 | 0 | 90 | 0 | -90 | |
| 7 | 0 | 90 | 0 | 90 | |
| 8 (Virtual Axis) | 0 | -90 | 105 | 0 | (6F) Integrated 6-DoF Force |
Note: offset is the deviation between the mechanical zero position and the modeling zero position, i.e. model angle = joint angle + offset.
Kinetic Parameters of RX75S Series Link
Left Arm:
| joint_id(i) | 1 | 2 | 3 | 4 | 5 | 6 | 7 |
|---|---|---|---|---|---|---|---|
| 1.821 | 1.774 | 1.346 | 1.062 | 1.027 | 0.637 | 0.149 | |
| -0.138 | 0.688 | 0.217 | -0.009 | 0.449 | -0.002 | -0.073 | |
| -0.982 | -98.869 | -0.308 | 89.133 | -0.689 | -0.177 | -26.804 | |
| -12.182 | -1 | -16.346 | -1.106 | -86.584 | -0.105 | -23.401 | |
| 3317 | 25123 | 3062 | 11678 | 9375 | 356 | 388 | |
| -9 | 103 | -9 | 0 | -16 | 0 | 0 | |
| 0 | 0 | 2 | 0 | 11 | 0 | 0 | |
| 2995 | 2084 | 2706 | 977 | 9102 | 264 | 190 | |
| 16 | -73 | -43 | 22 | -70 | -2 | -37 | |
| 1904 | 24592 | 1251 | 11361 | 909 | 353 | 287 | |
| Remarks | 6-DoF Force |
Right Arm:
| joint_id(i) | 1 | 2 | 3 | 4 | 5 | 6 | 7 |
|---|---|---|---|---|---|---|---|
| 1.821 | 1.774 | 1.346 | 1.062 | 1.027 | 0.637 | 0.148 | |
| 0.138 | 0.719 | -0.201 | 0.002 | -0.456 | 0.002 | -0.072 | |
| 0.982 | -98.87 | 0.271 | 89.123 | -0.702 | -0.177 | 26.81 | |
| -12.182 | 1.075 | -16.361 | 1.105 | -86.593 | -0.103 | -23.405 | |
| 3317.16 | 25123.212 | 3067.296 | 11676.82 | 9375.907 | 356.792 | 388.712 | |
| -9.367 | 109.695 | -9.912 | -0.226 | 16.367 | -0.059 | 0.61 | |
| 0.038 | -0.537 | -1.357 | 0.028 | -12.383 | -0.019 | 0.003 | |
| 2995.229 | 2084.447 | 2706.245 | 977.818 | 9103.613 | 264.819 | 190.275 | |
| -16.96 | 88.782 | 43.058 | -22.008 | -71.308 | -2.907 | 37.575 | |
| 1904.144 | 24593.133 | 1255.706 | 11360.69 | 908.896 | 353.513 | 287.644 | |
| Remarks | 6-DoF Force |
Description:
: Mass of the link, unit: : X-coordinate of the center of mass of the link, unit: : Y-coordinate of the center of mass of the link, unit: : Z-coordinate of the center of mass of the link, unit: , , , , , : Principal moments of inertia described in the link coordinate system, unit:
Remarks:
- Data above are sourced from CAD design values.
- If inertial parameters in the center of mass coordinate system are required, the Parallel Axis Theorem can be used. The calculation method is described as follows.
Assuming an output coordinate system
Where:
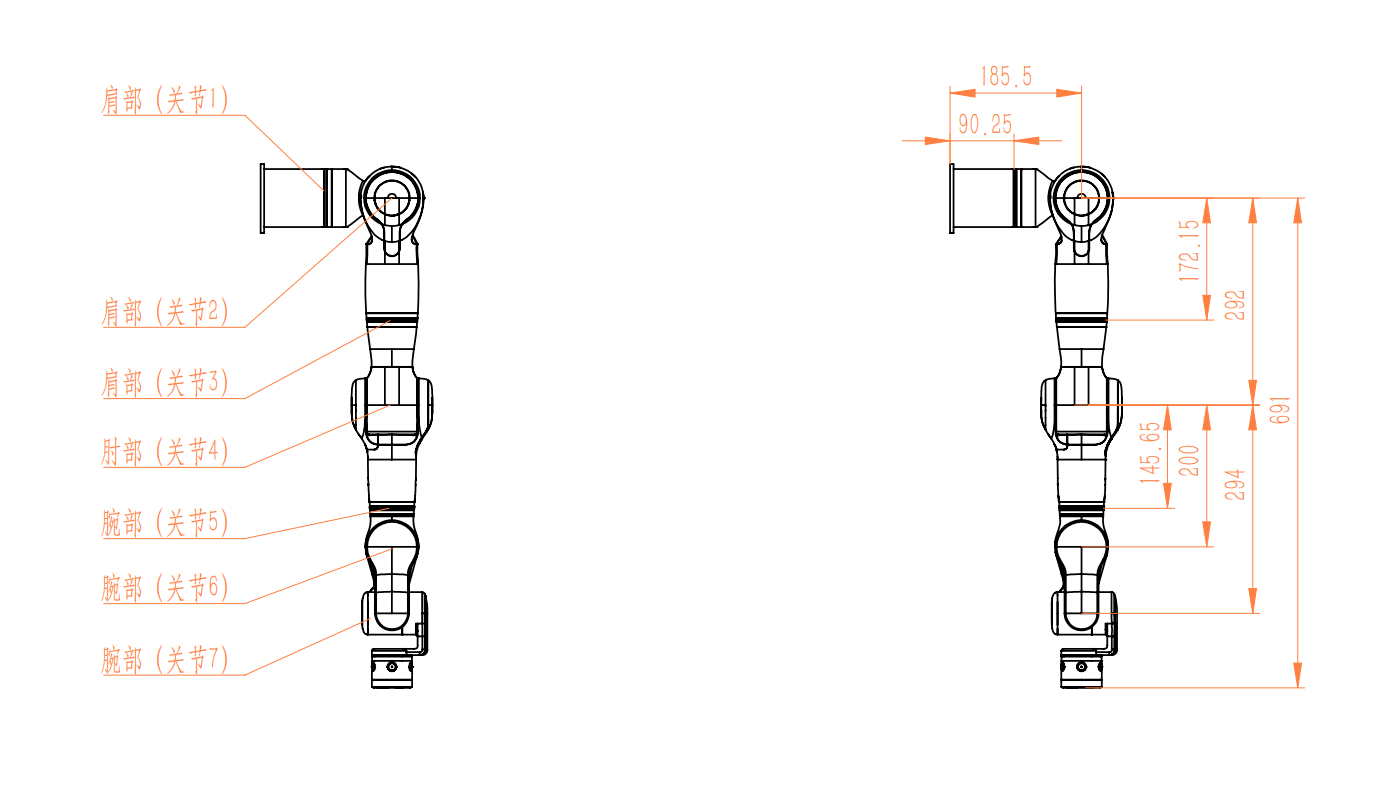
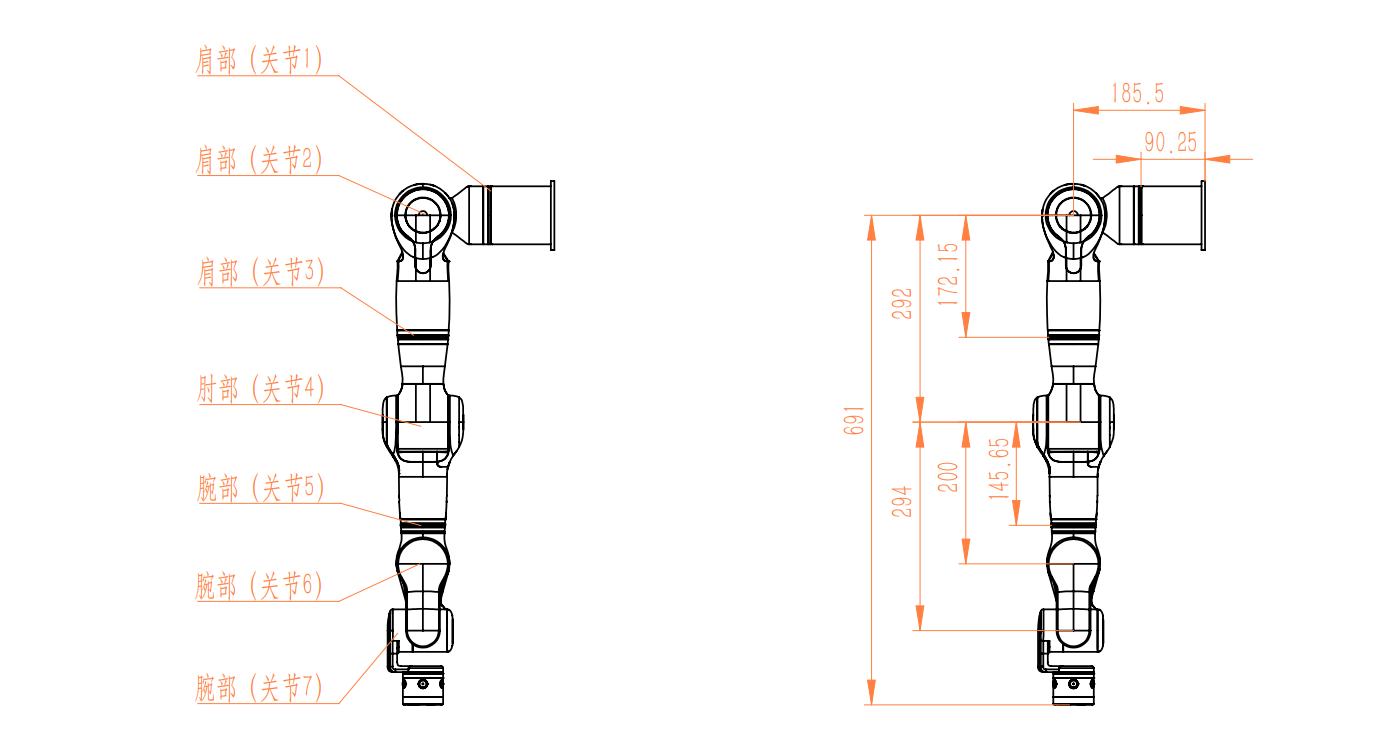
Joint Distribution and Dimension Description
The RX75S robot body has 7 rotational joints, each representing one degree of freedom. As shown in the figure below, the robot joints include shoulder (joint 1), shoulder (joint 2), shoulder (joint 3), elbow (joint 4), wrist (joint 5), wrist (joint 6) and wrist (joint 7).
Joint Distribution:
| Left Arm | Right Arm |
|---|---|
 |  |
Workspace
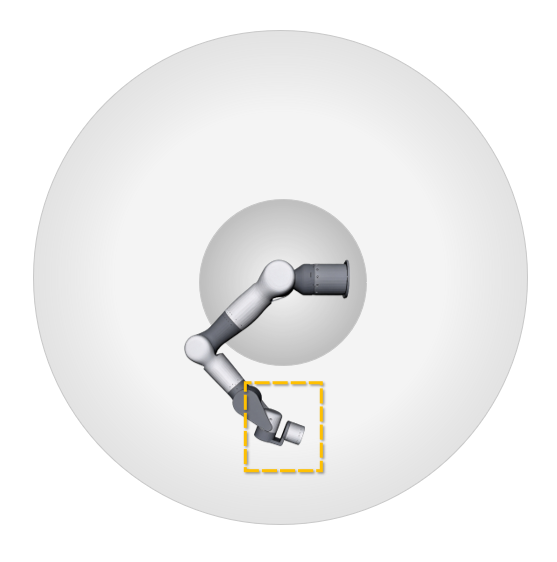
Excluding the cylindrical space directly above and below the base, the workspace of RX75S is a sphere with a radius of 691 mm. When selecting the robot installation position, be sure to consider the cylindrical space directly above and below the robot and avoid moving the tool into this area as much as possible.
Workspace:
| Left Arm | Right Arm |
|---|---|
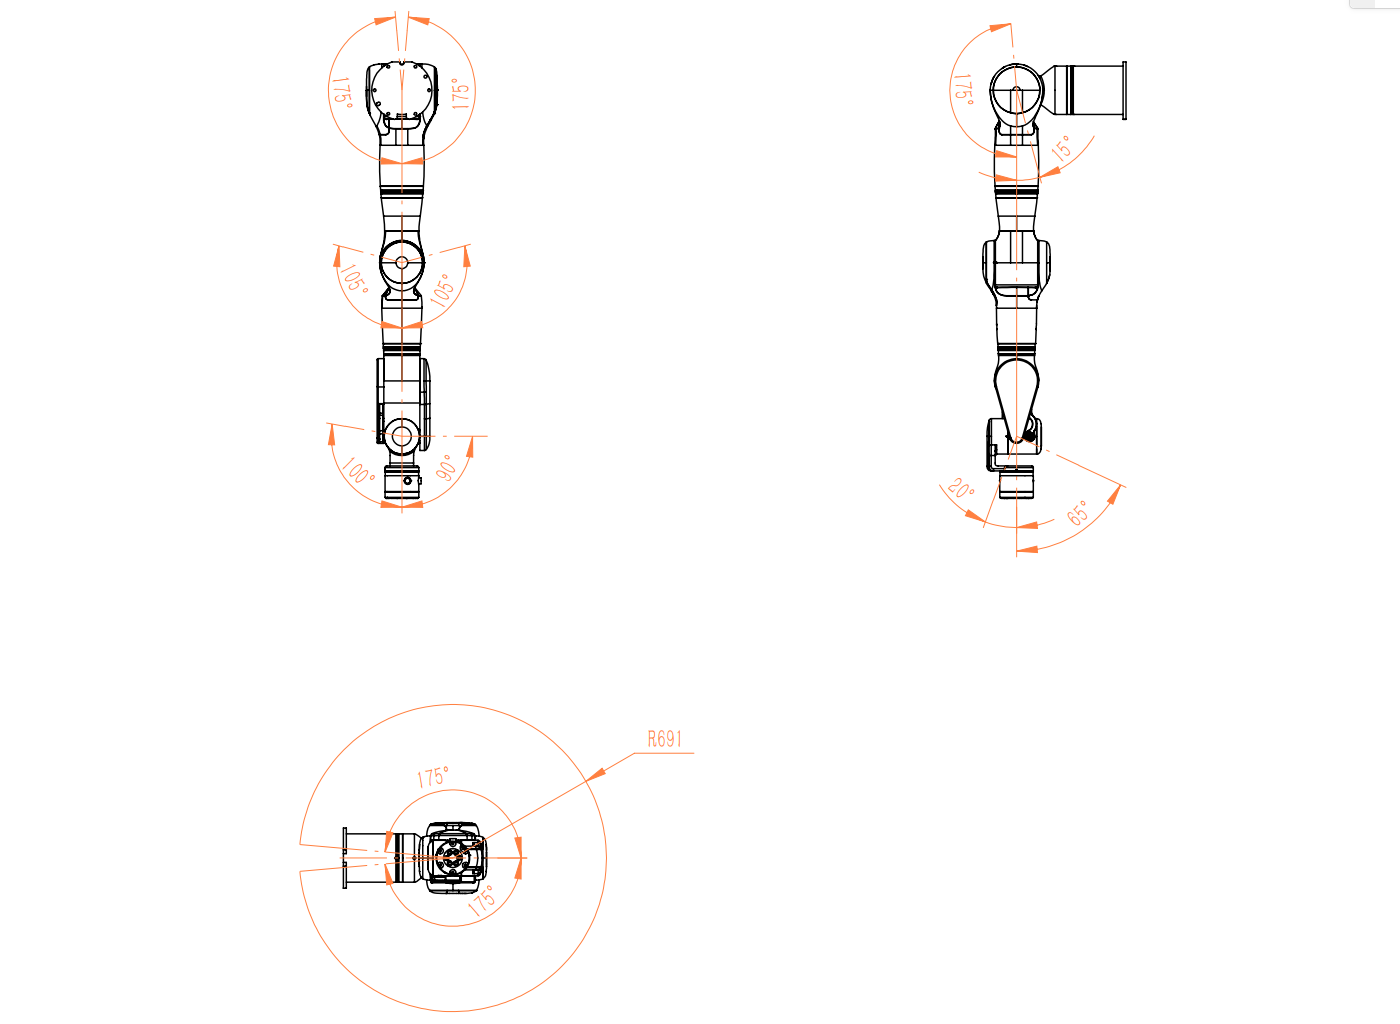 |  |
From the workspace cross-section, the area with better operability of the 7-axis robot is shown by the yellow frame in the figure below, presenting an annular region in the workspace as a whole.
Motion Singularities
Left Arm: RXL75S
Singularity Type 1
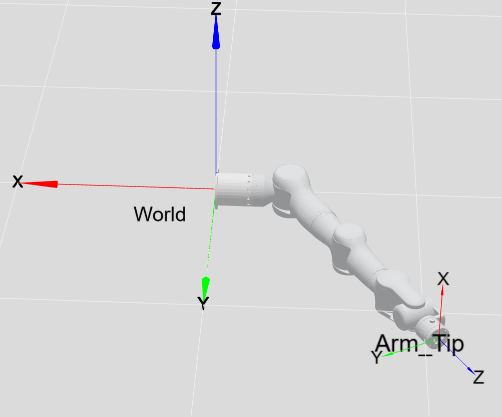
When q4=0, i.e., the point format is [x,x,x,0,x,x,x].
Example point 1: [-90,30,-90,0,90,0,0], as shown in the figure below:
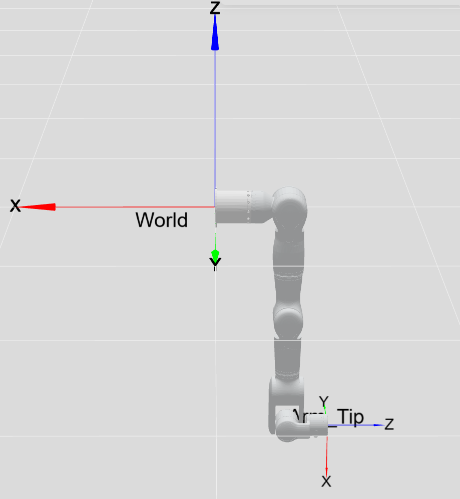
Example point 2: [0,0,90,0,0,0,-90], as shown in the figure below:
Singularity Type 2
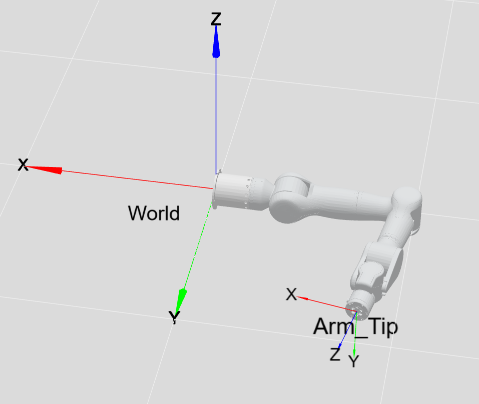
When q2=90 and q3=0 (or q3=180), i.e., the point format is [x,90,0 or 180,x,x,x,x].
Example point 1: [-90,90,0,-90,0,0,0], as shown in the figure below:
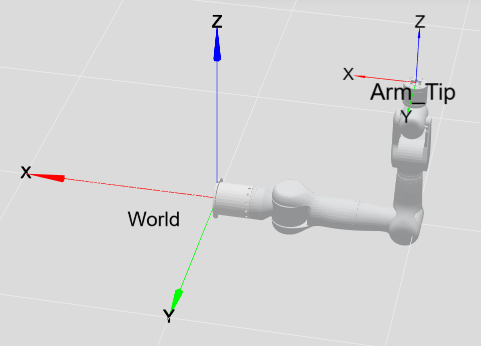
Example point 2: [0,90,0,-100,0,0,0], as shown in the figure below:
Right Arm: RXR75S
Singularity Type 1
When q4=0, i.e., the point format is [x,x,x,0,x,x,x].
Example point 1: [90,30,-90,0,90,0,0], as shown in the figure below:
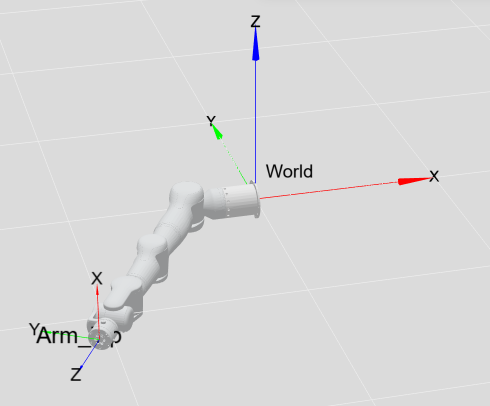
Example point 2: [0,0,90,0,0,0,90], as shown in the figure below:
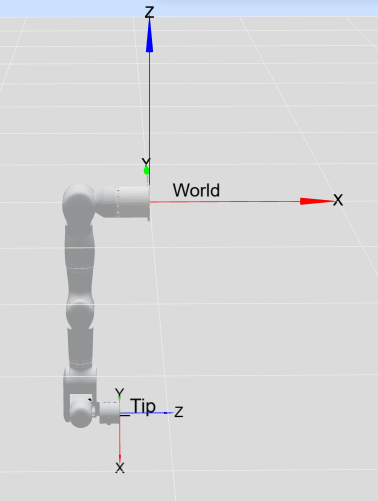
Singularity Type 2
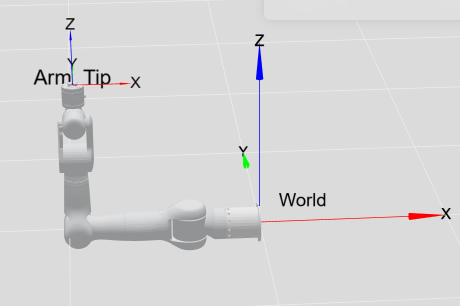
When q2=90 and q3=0 (or q3=180), i.e., the point format is [x,90,0 or 180,x,x,x,x].
Example point 1: [90,90,0,-90,0,0,0], as shown in the figure below:
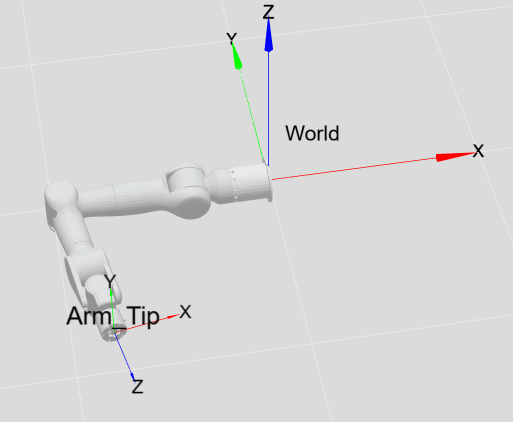
Example point 2: [0,90,0,-100,0,0,0], as shown in the figure below:
Load Curve
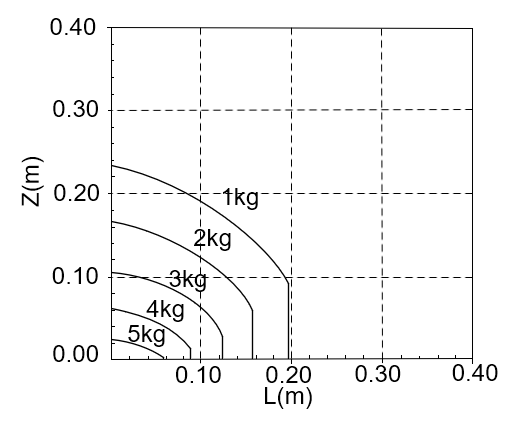
The figure below shows the end load curve of the RX75S robotic arm. L is the radial distance of the center of mass of the end load relative to the end flange plane, and Z is the normal distance relative to the end flange plane.